Hardware Specifications
Exoskeleton V2
| Attribute | Specification |
|---|---|
| Dimensions | 20 × 15 × 10 cm |
| Weight | 195 ± 5 g |
| Joint count | 21 |
| Wear time | Ready in ~5 seconds |
| Feedback | 10-level vibration on 5 fingers |
| Glove sizes | S/M |
| Connection | Wired direct / wireless module |
| Operating voltage | 5 V |
| Battery life | 2.5–3 H (shared with wireless module) |
| Environment | Operating temp: 0 °C ~ 40 °C; storage temp: -20 °C ~ 60 °C; humidity: 10%~90% non-condensing; storage humidity: 5%~95% non-condensing |
| Data output | Encoders / accelerometer / gyroscope |
| Data rate | 120 Hz |
| Magnetic encoder accuracy | 1.0 ± 0.2° |
| Accelerometer range | ± 16 g |
| Gyroscope range | ± 2000 deg/s |
Accessories
Wireless (Wi-Fi) Module

Wireless module appearance
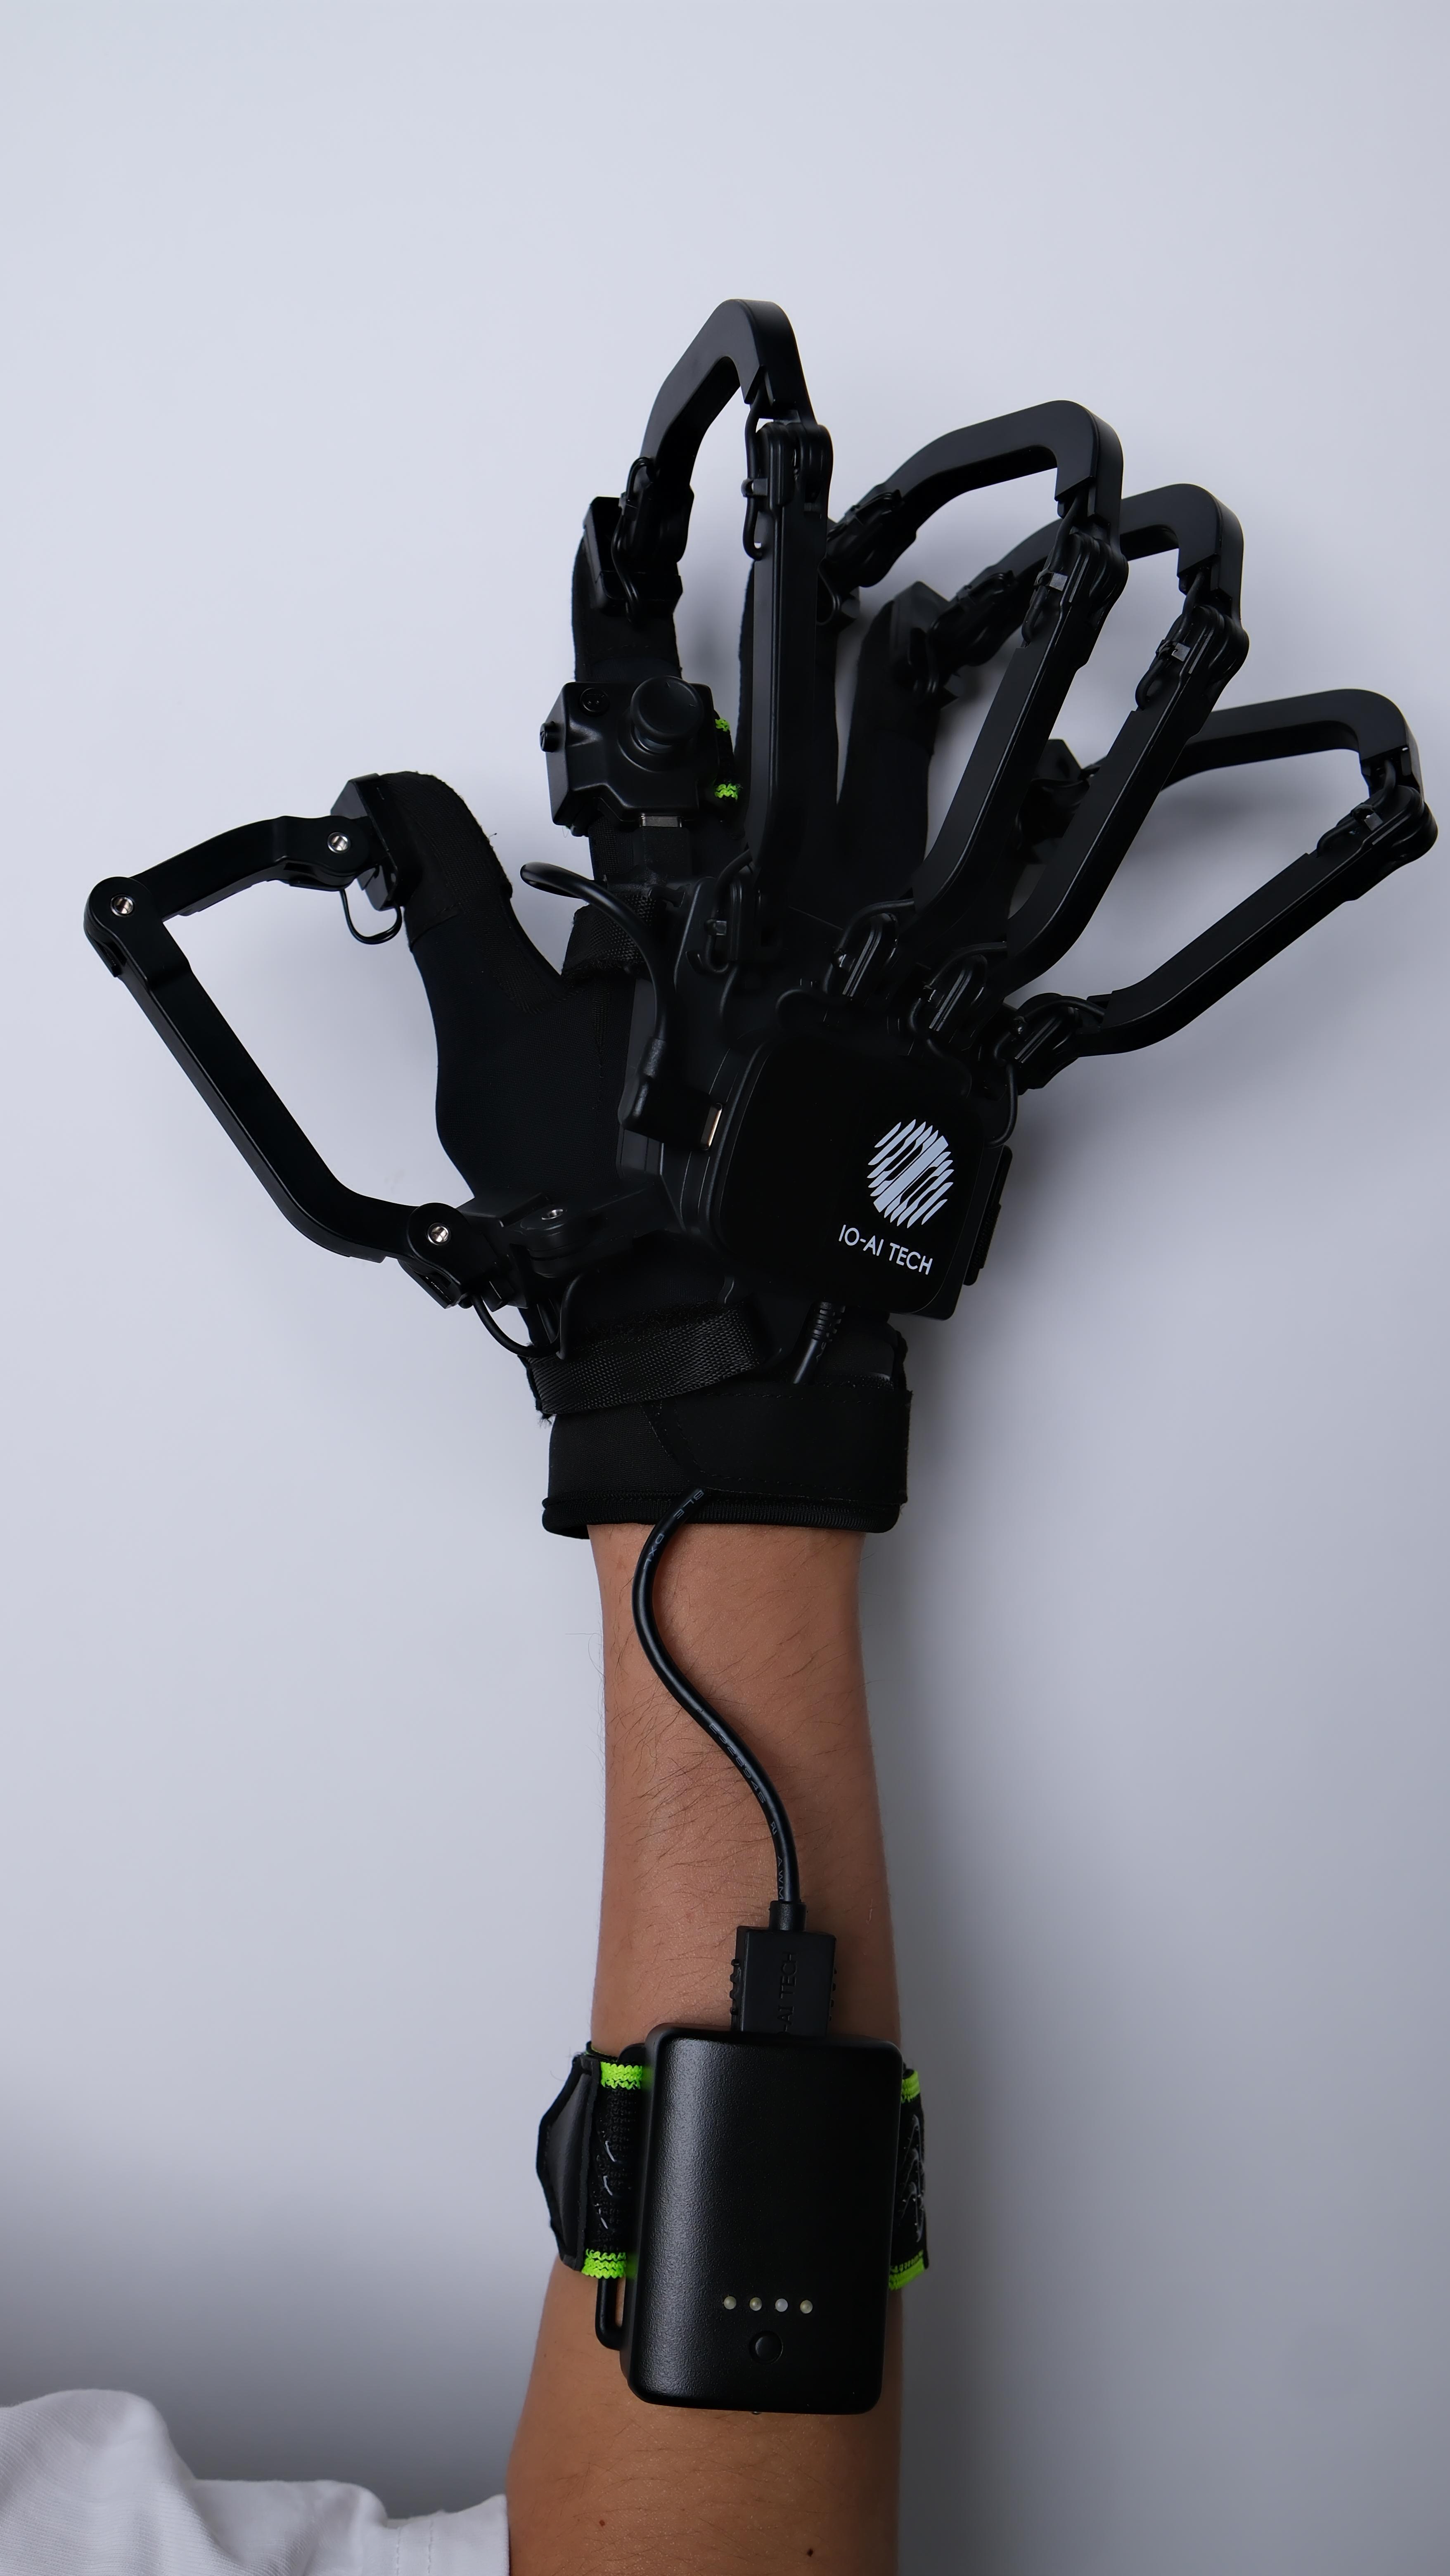
Connection and wearing effect
Hand-back mounting structure (Pico)

Hand-back mounting structure (Pico) appearance
Hand-back mounting structure (Vive)
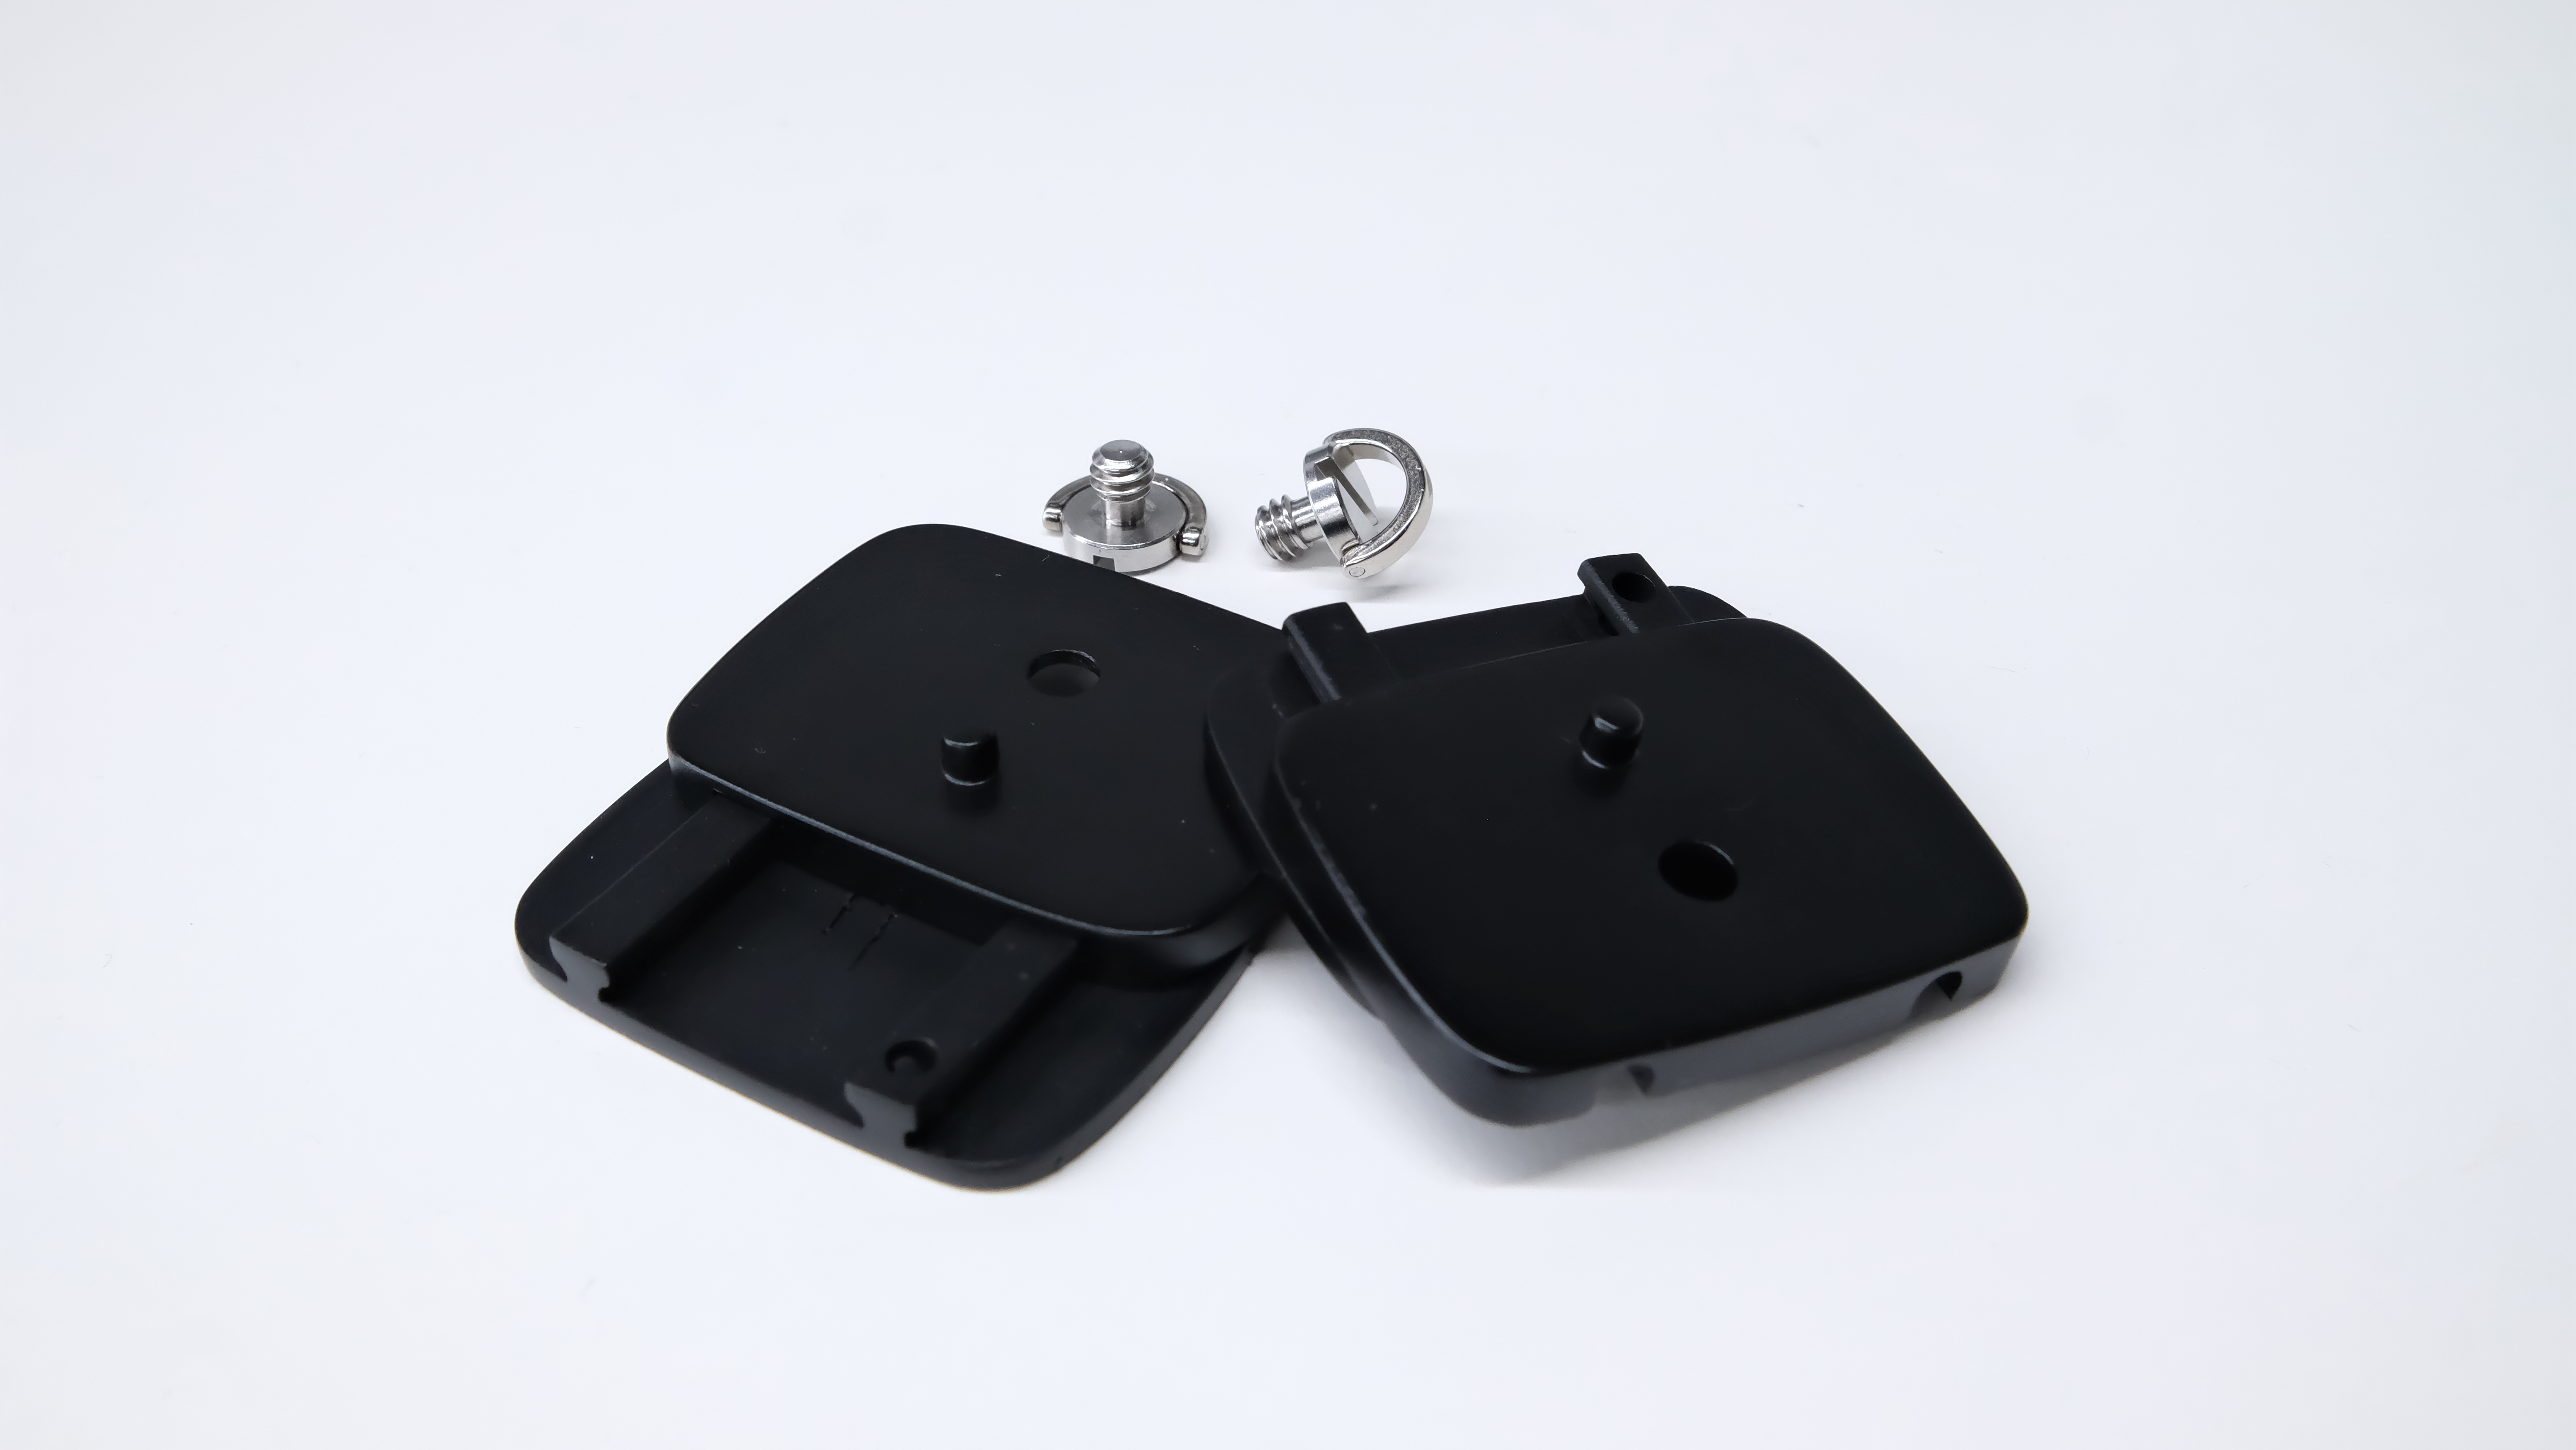
Hand-back mounting structure (Vive) appearance
Installation Tutorial
Hand-back mounting structure (Vive) installation tutorial
Finger control unit

Finger control unit appearance

Connection and wearing effect
Coordinate Systems of Mounting Structures
Hand-back mounting structure (Pico)
#Quaternion [x, y, z, w]
#Euler angles XYZ Extrinsic
# from left_hand to Lgamepad
- Translation: [0.083, -0.026, 0.068]
- Rotation: in Quaternion [0.888, 0.223, 0.403, 0.001]
- Rotation: in RPY (radian) [2.880, -0.797, 0.603]
- Rotation: in RPY (degree) [164.983, -45.684, 34.544]
- Matrix:
  0.575  0.395  0.716  0.083
  0.396 -0.901  0.178 -0.026
  0.716  0.181 -0.675  0.068
  0.000  0.000  0.000  1.000

# from right_hand to Rgamepad
- Translation: [-0.083, -0.026, 0.068]
- Rotation: in Quaternion [0.888, -0.223, -0.403, 0.001]
- Rotation: in RPY (radian) [2.880, 0.797, -0.603]
- Rotation: in RPY (degree) [164.983, 45.684, -34.544]
- Matrix:
  0.575 -0.395 -0.716 -0.083
 -0.396 -0.901  0.178 -0.026
 -0.716  0.181 -0.675  0.068
  0.000  0.000  0.000  1.000
Lgamepad right-handed coordinate system
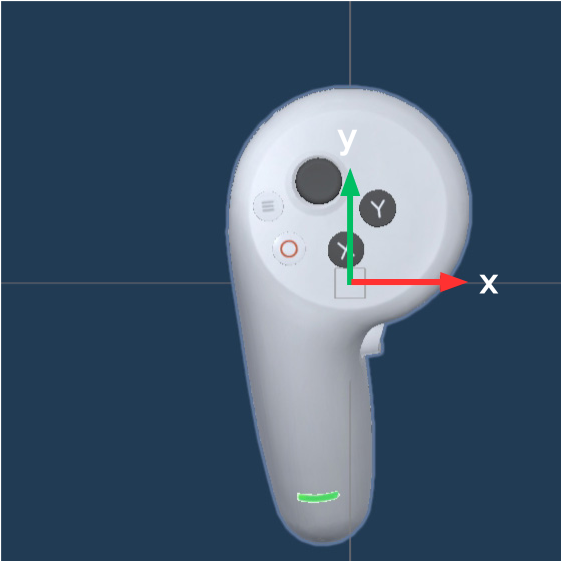 | 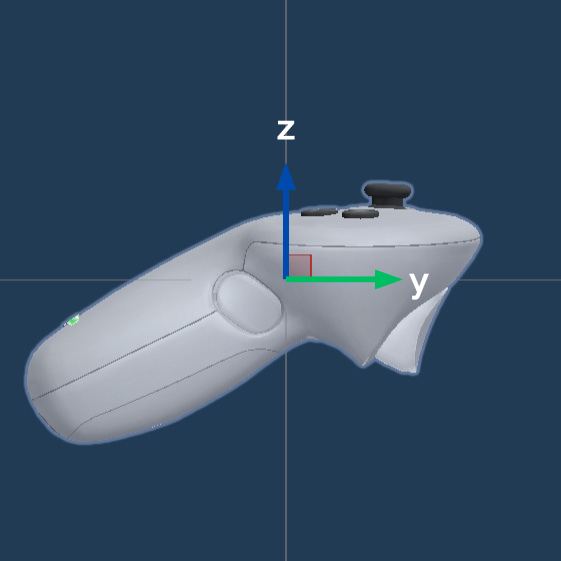 | 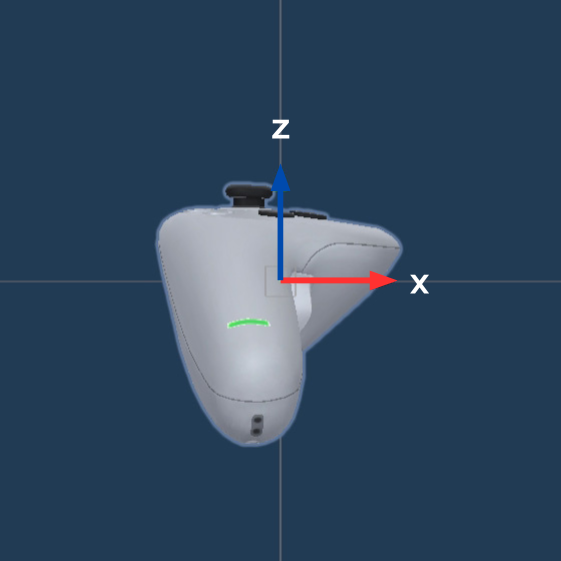 |
Rgamepad right-handed coordinate system
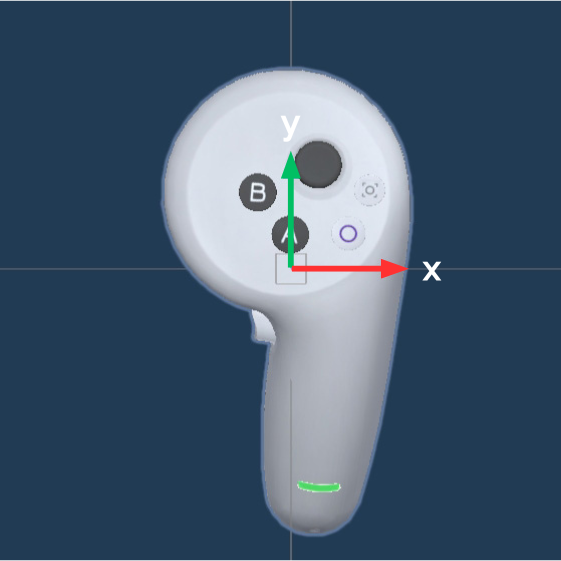 | 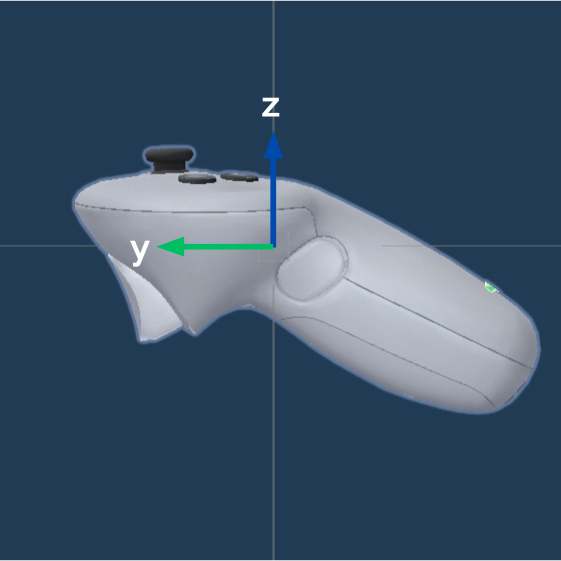 | 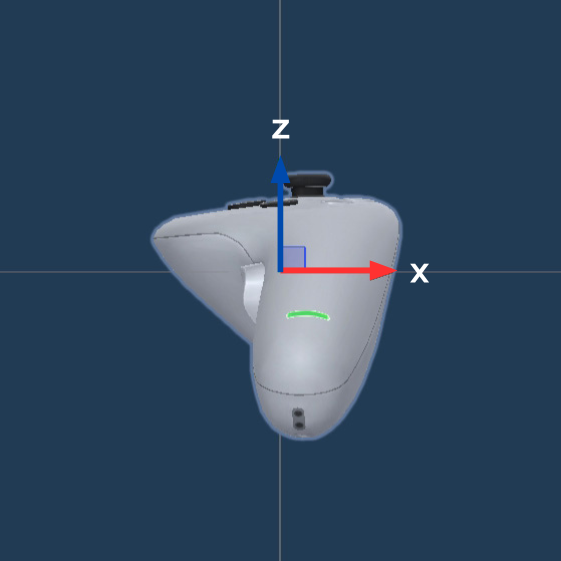 |
Hand-back mounting structure (Vive)
#Quaternion [x, y, z, w]
#Euler angles XYZ Extrinsic
# from left_hand to L_vive_tracker
- Translation: [0.004, -0.000, 0.046]
- Rotation: in Quaternion [-0.040, 0.706, 0.706, -0.040]
- Rotation: in RPY (radian) [1.571, 0.000, -3.027]
- Rotation: in RPY (degree) [90.000, 0.000, -173.437]
- Matrix:
  -0.993 -0.000 -0.114  0.004
  -0.114  0.000  0.993 -0.000
  0.000   1.000 -0.000  0.046
  0.000   0.000  0.000  1.000

# from right_hand to R_vive_tracker
- Translation: [-0.004, -0.000, 0.046]
- Rotation: in Quaternion [0.041, 0.706, 0.706, 0.041]
- Rotation: in RPY (radian) [1.571, -0.000, 3.025]
- Rotation: in RPY (degree) [90.000, -0.000, 173.323]
- Matrix:
  -0.993 0.000  0.116 -0.004
  0.116  0.000  0.993 -0.000
  0.000  1.000  -0.000 0.046
  0.000  0.000  0.000  1.000
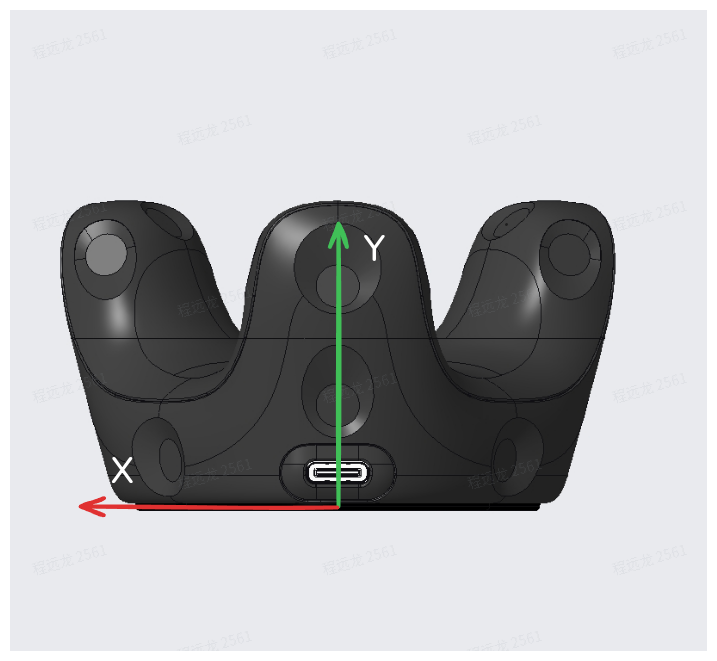
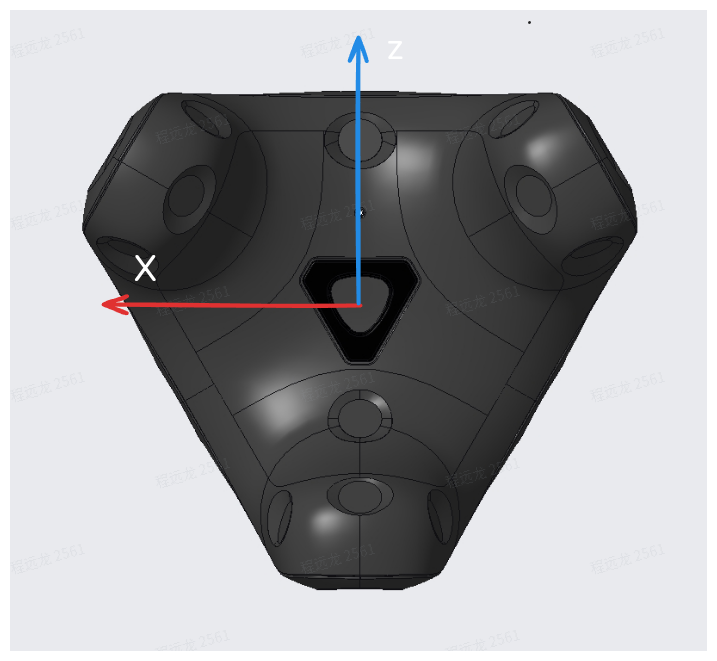
L_vive_tracker right-handed coordinate system
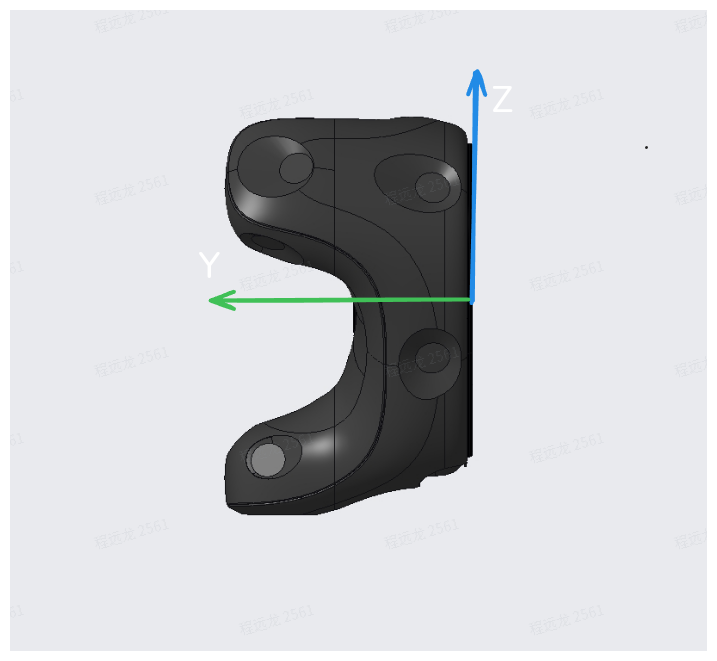 | 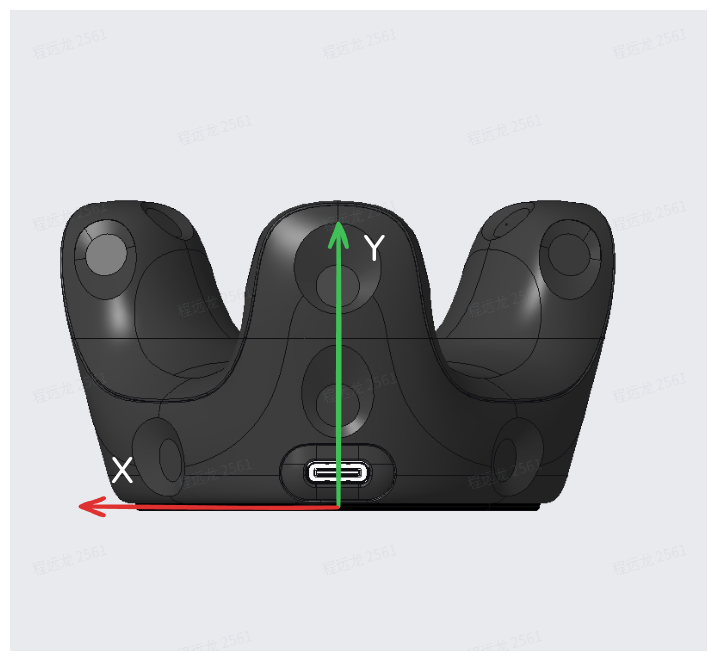 | 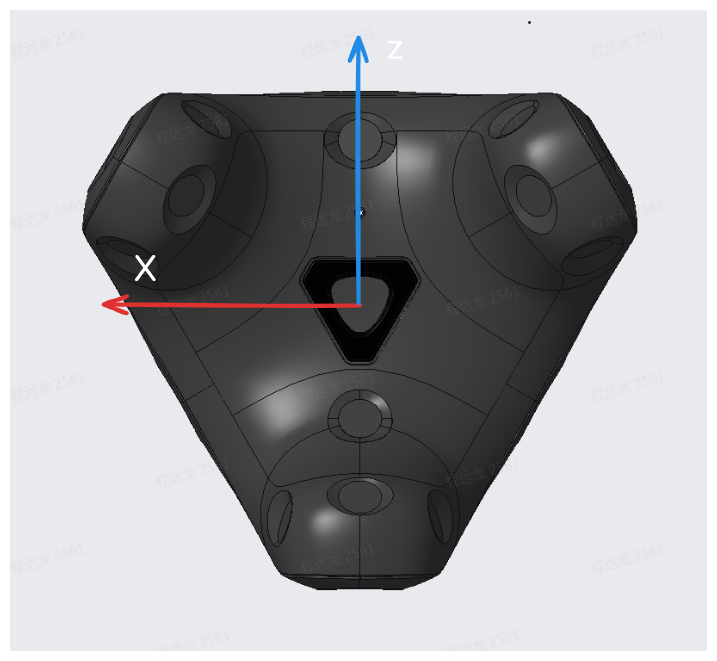 |
R_vive_tracker right-handed coordinate system
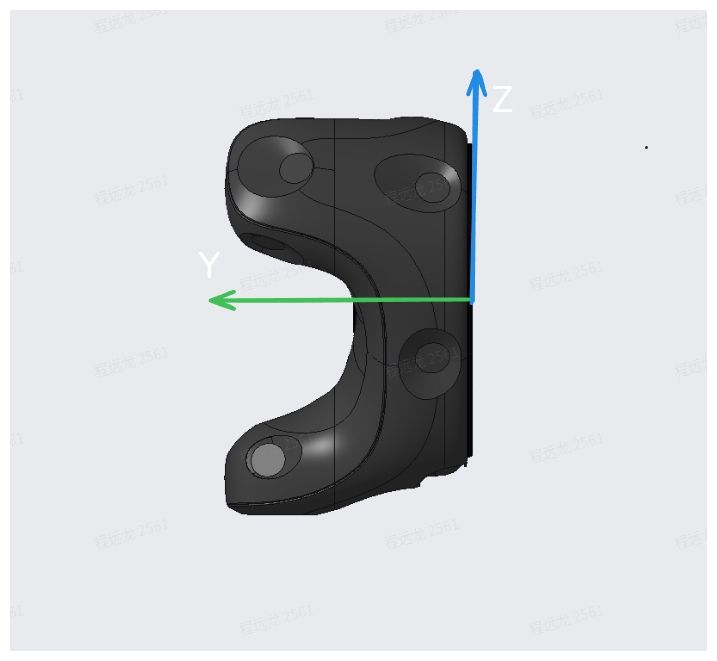 |  |  |
Hand-back mounting structure (Sonic)
#Quaternion [x, y, z, w]
#Euler angles XYZ Extrinsic
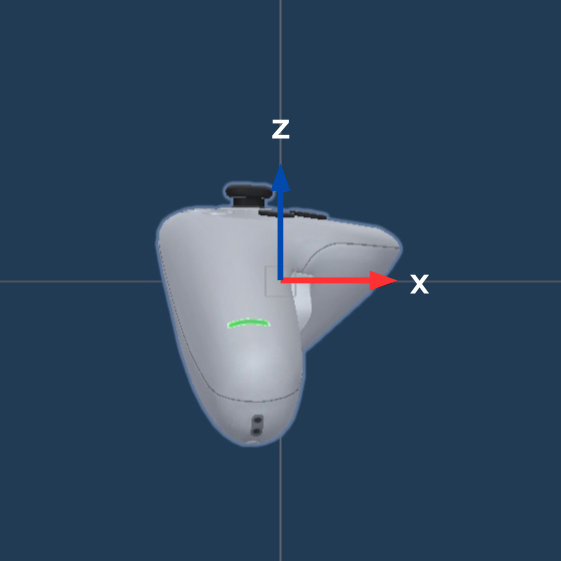
# from left_hand to L_SONIC
- Translation: [-0.003, -0.034, 0.068]
- Rotation: in Quaternion [0.123, 0.696, 0.152, 0.691]
- Rotation: in RPY (radian) [1.571, -1.179, -1.614]
- Rotation: in RPY (degree) [90.000, -67.535, -92.478]
- Matrix:
 -0.016 -0.038  0.999 -0.003
  0.382  0.923  0.042 -0.034
 -0.924  0.382 -0.000  0.068
  0.000  0.000  0.000  1.000

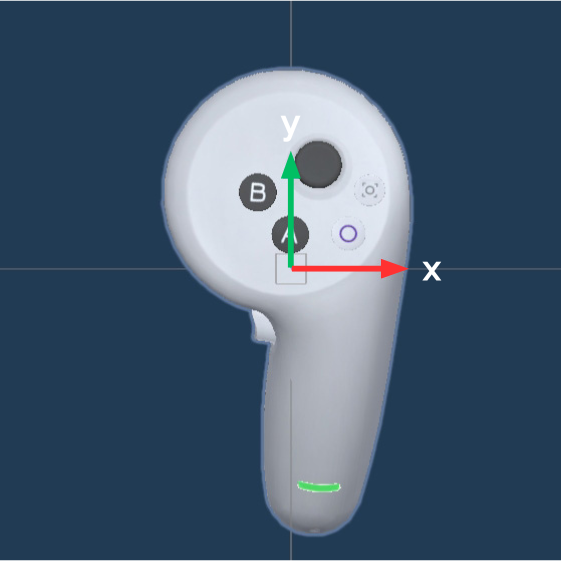
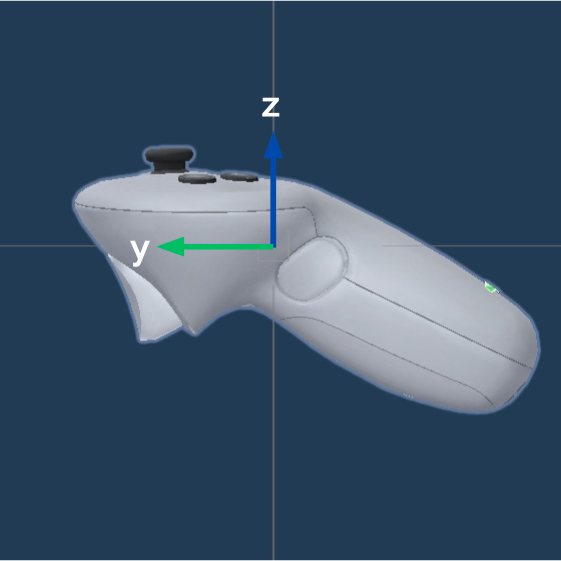
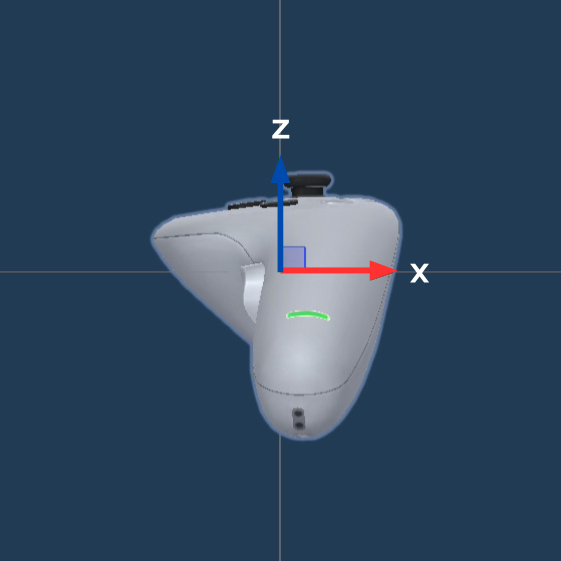
# from right_hand to R_SONIC
- Translation: [0.003, -0.034, 0.068]
- Rotation: in Quaternion [0.123, -0.696, -0.153, 0.690]
- Rotation: in RPY (radian) [1.571, -1.179, -1.614]
- Rotation: in RPY (degree) [90.000, -67.535, -92.478]
- Matrix:
 -0.016 -0.038  0.999 -0.003
  0.382  0.923  0.042 -0.034
 -0.924  0.382 -0.000  0.068
  0.000  0.000  0.000  1.000
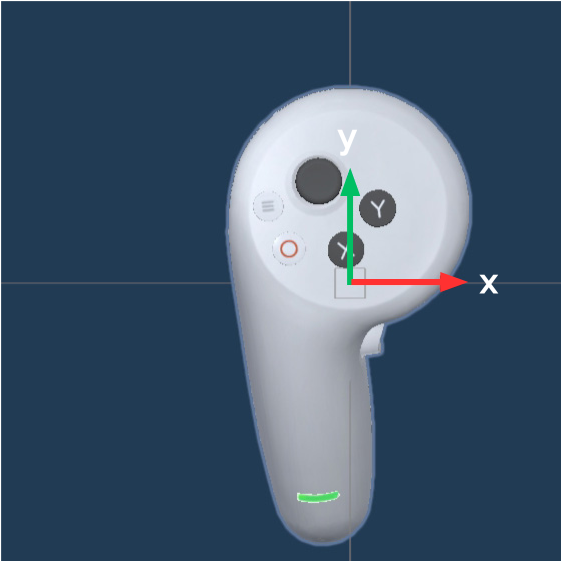
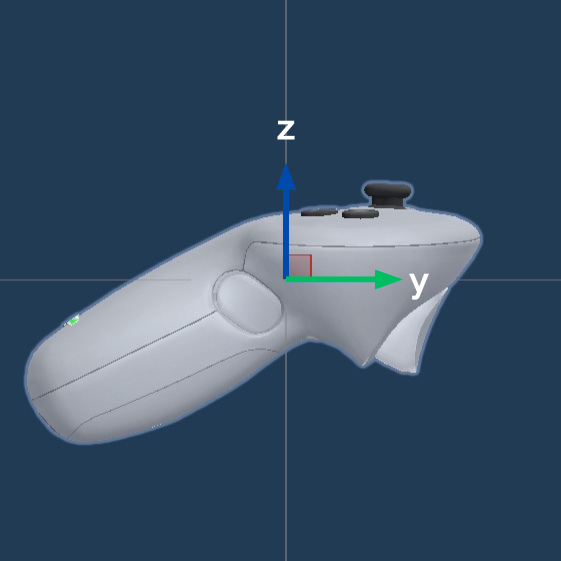
L_SONIC right-handed coordinate system
 |  |  |
R_SONIC right-handed coordinate system
 |  |  |